Scientist & Builder

I build and lead research teams, turning advances in reinforcement learning into working systems.

I’ve worked on reasoning in Gemini, learning from demonstrations, and control systems that have to work beyond a benchmark. Away from the keyboard: surfing, sailing, climbing, and a few collective projects.

Now: Founding Research Scientist at UMA ↗

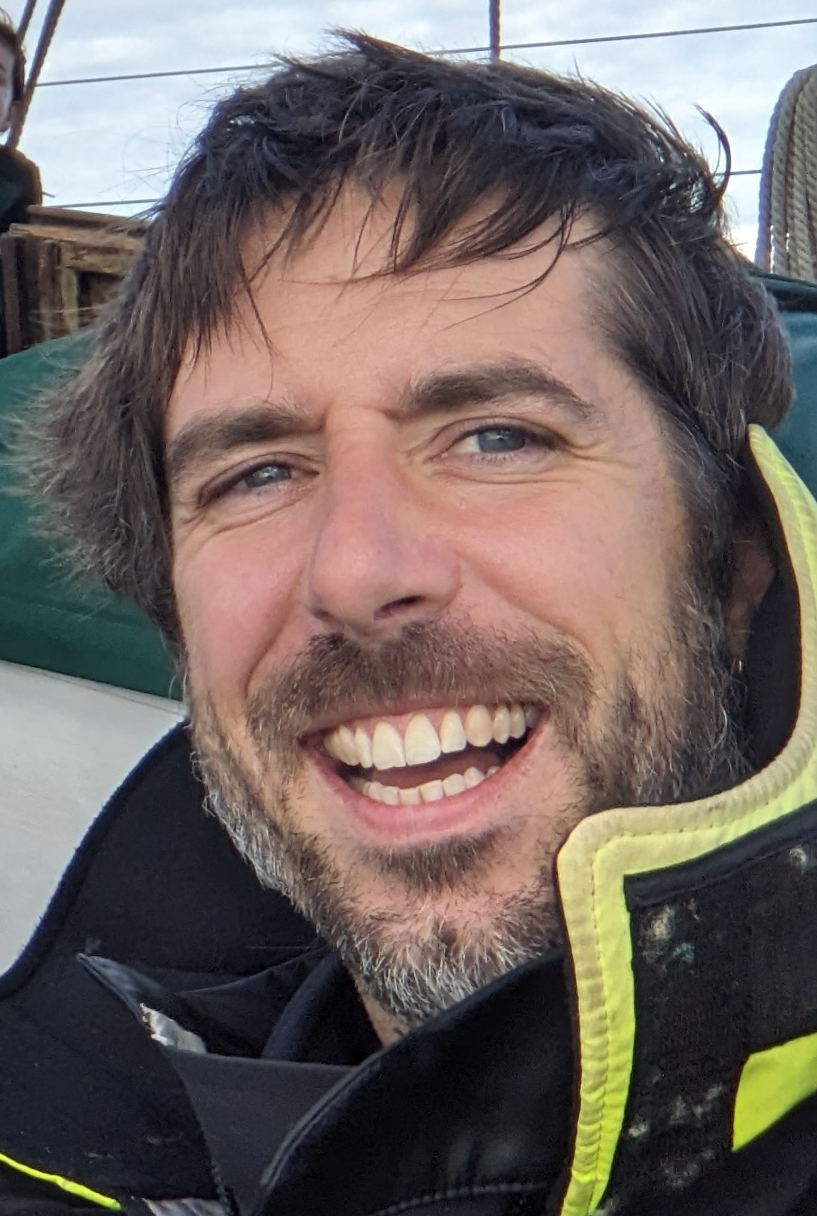
Gabriel smiling aboard a sailboat.

Reasoning & post-training

Gemini Thinking

Helped build and co-led an early team contributing to reasoning in Gemini, developing RL methods and the science and infrastructure for experiments.
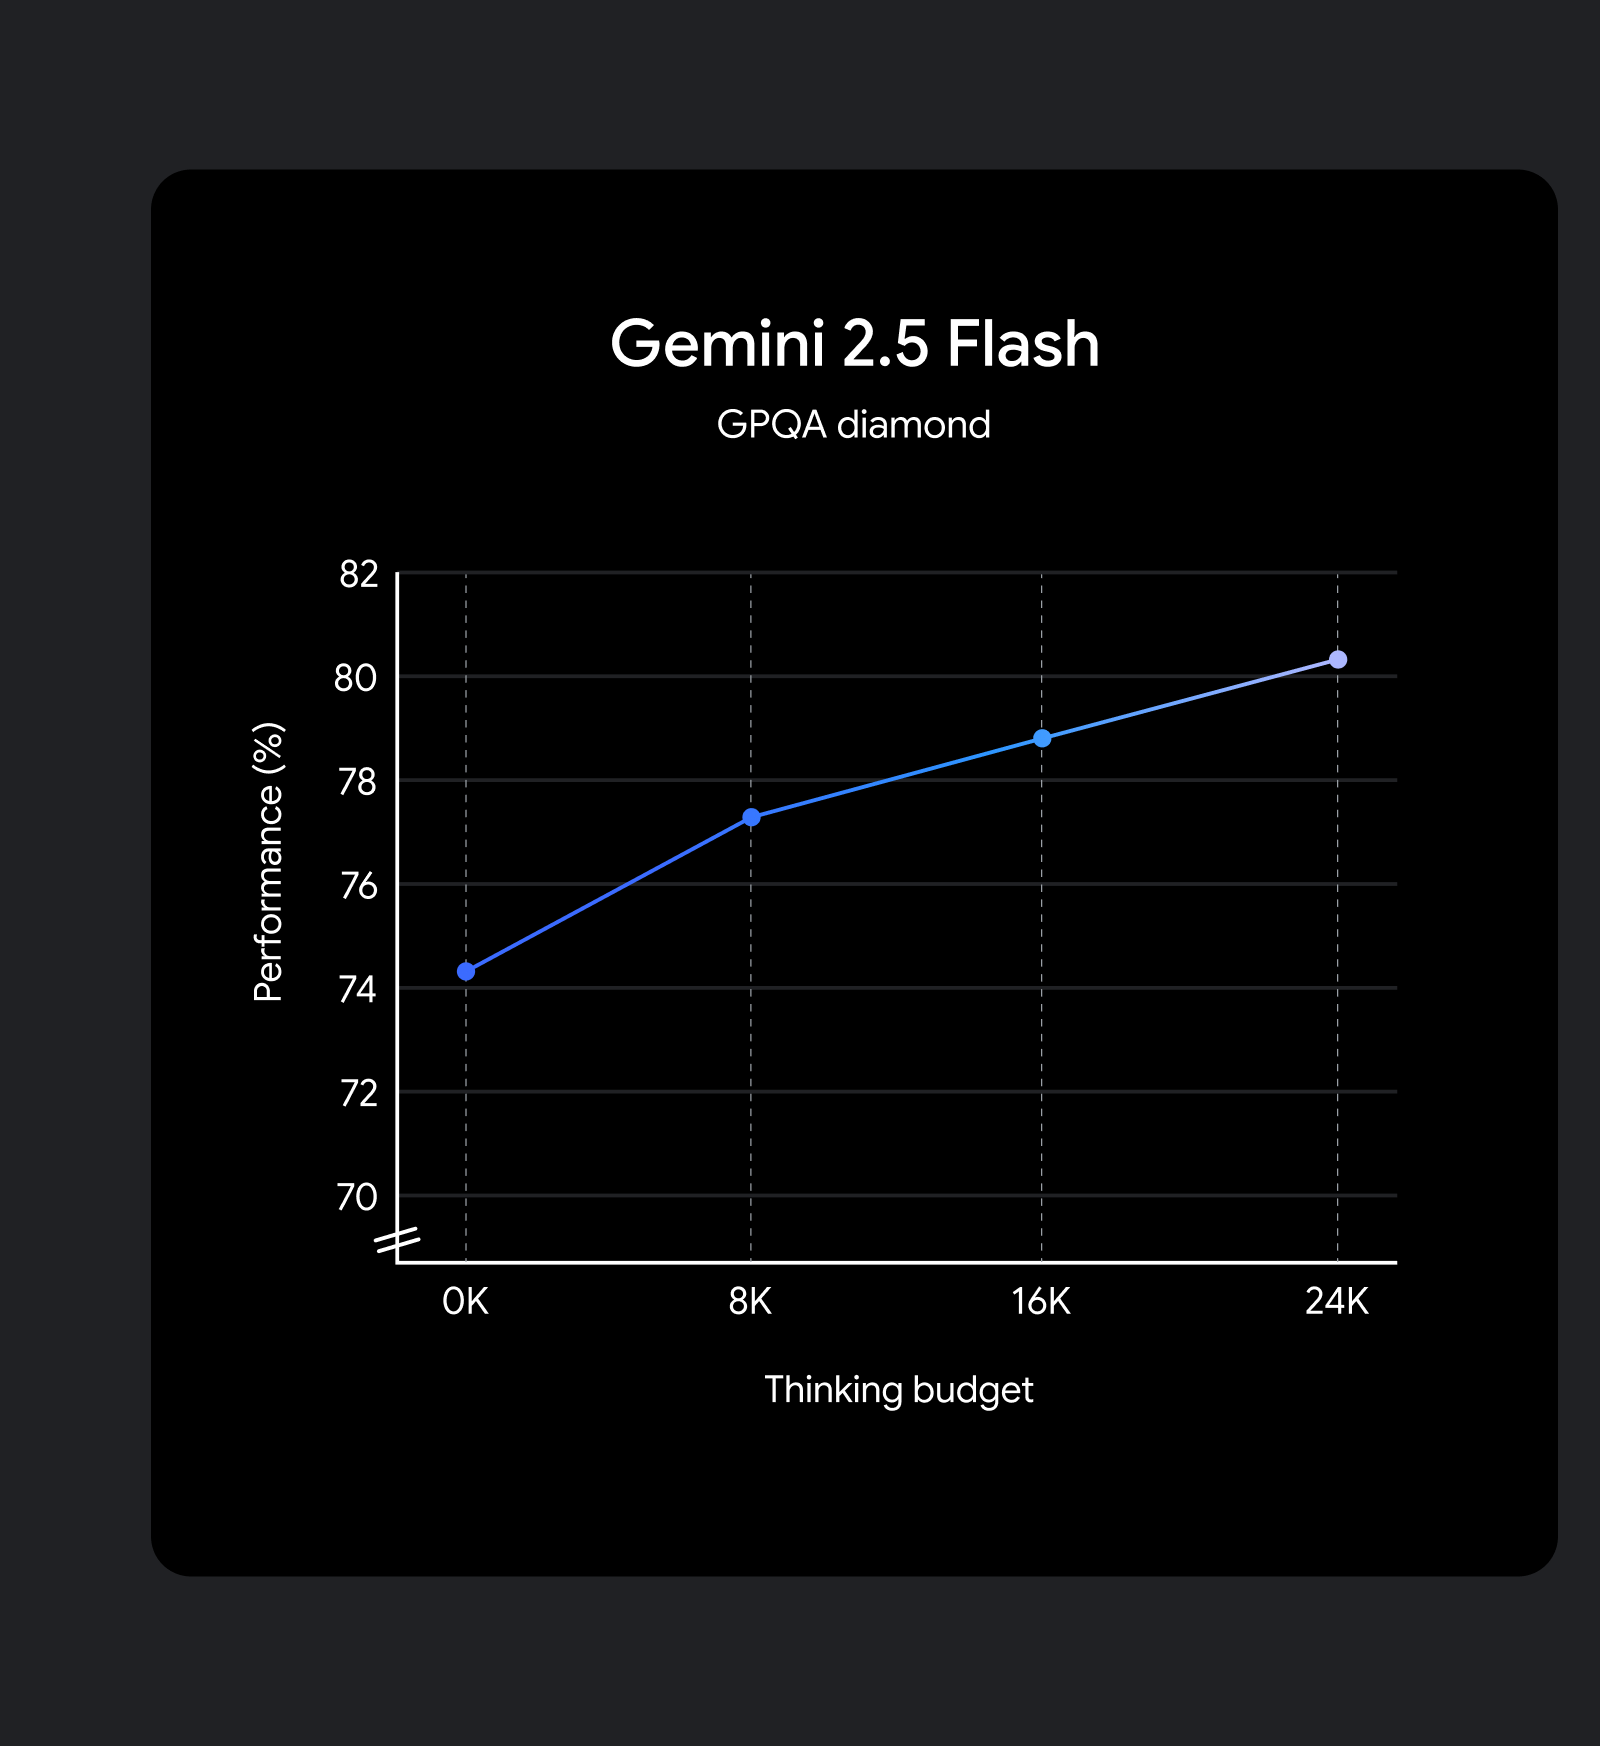
Gemini 2.5 Flash on GPQA Diamond: performance rises from about 74% to 80% as the thinking budget increases from 0K to 24K tokens.

GPQA Diamond performance with increasing thinking budget.
Gemini 2.5 Flash announcement · April 2025 ↗

Gemini Post-Training

Co-led a push on RL and token efficiency strategy, running the training that produced the September 2025 Gemini 2.5 Flash checkpoint. The release improved quality while using 24% fewer output tokens.
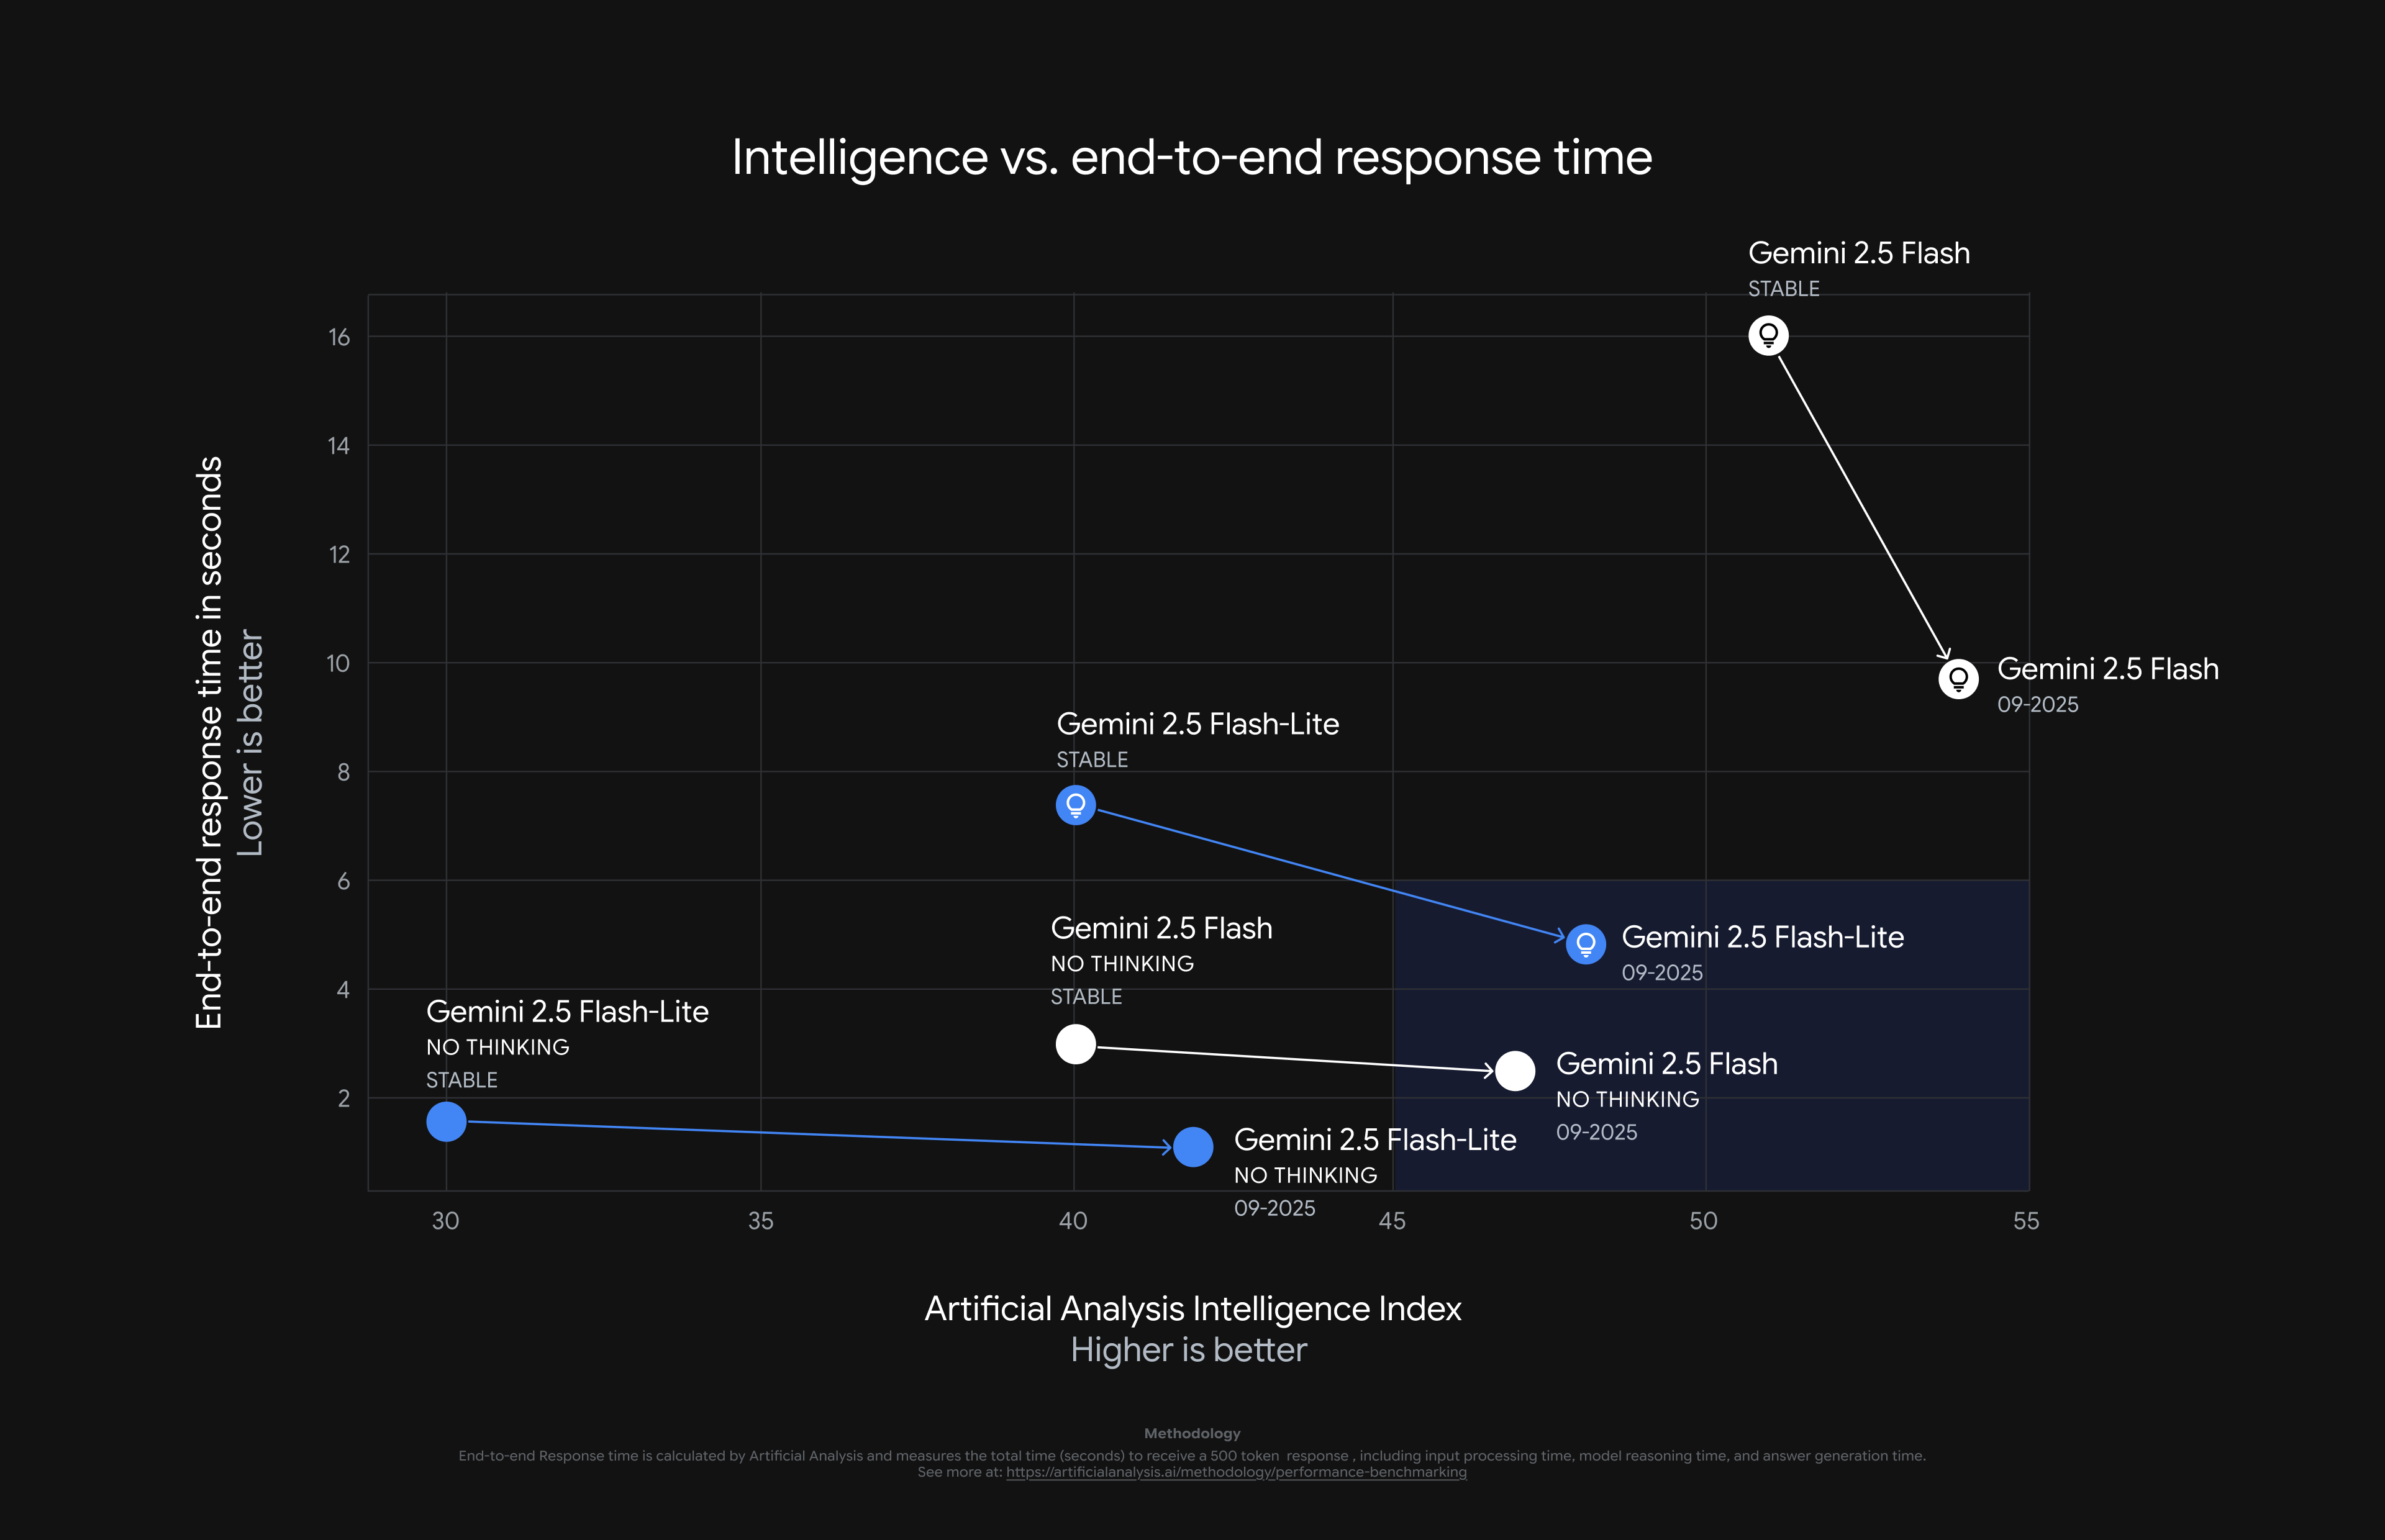
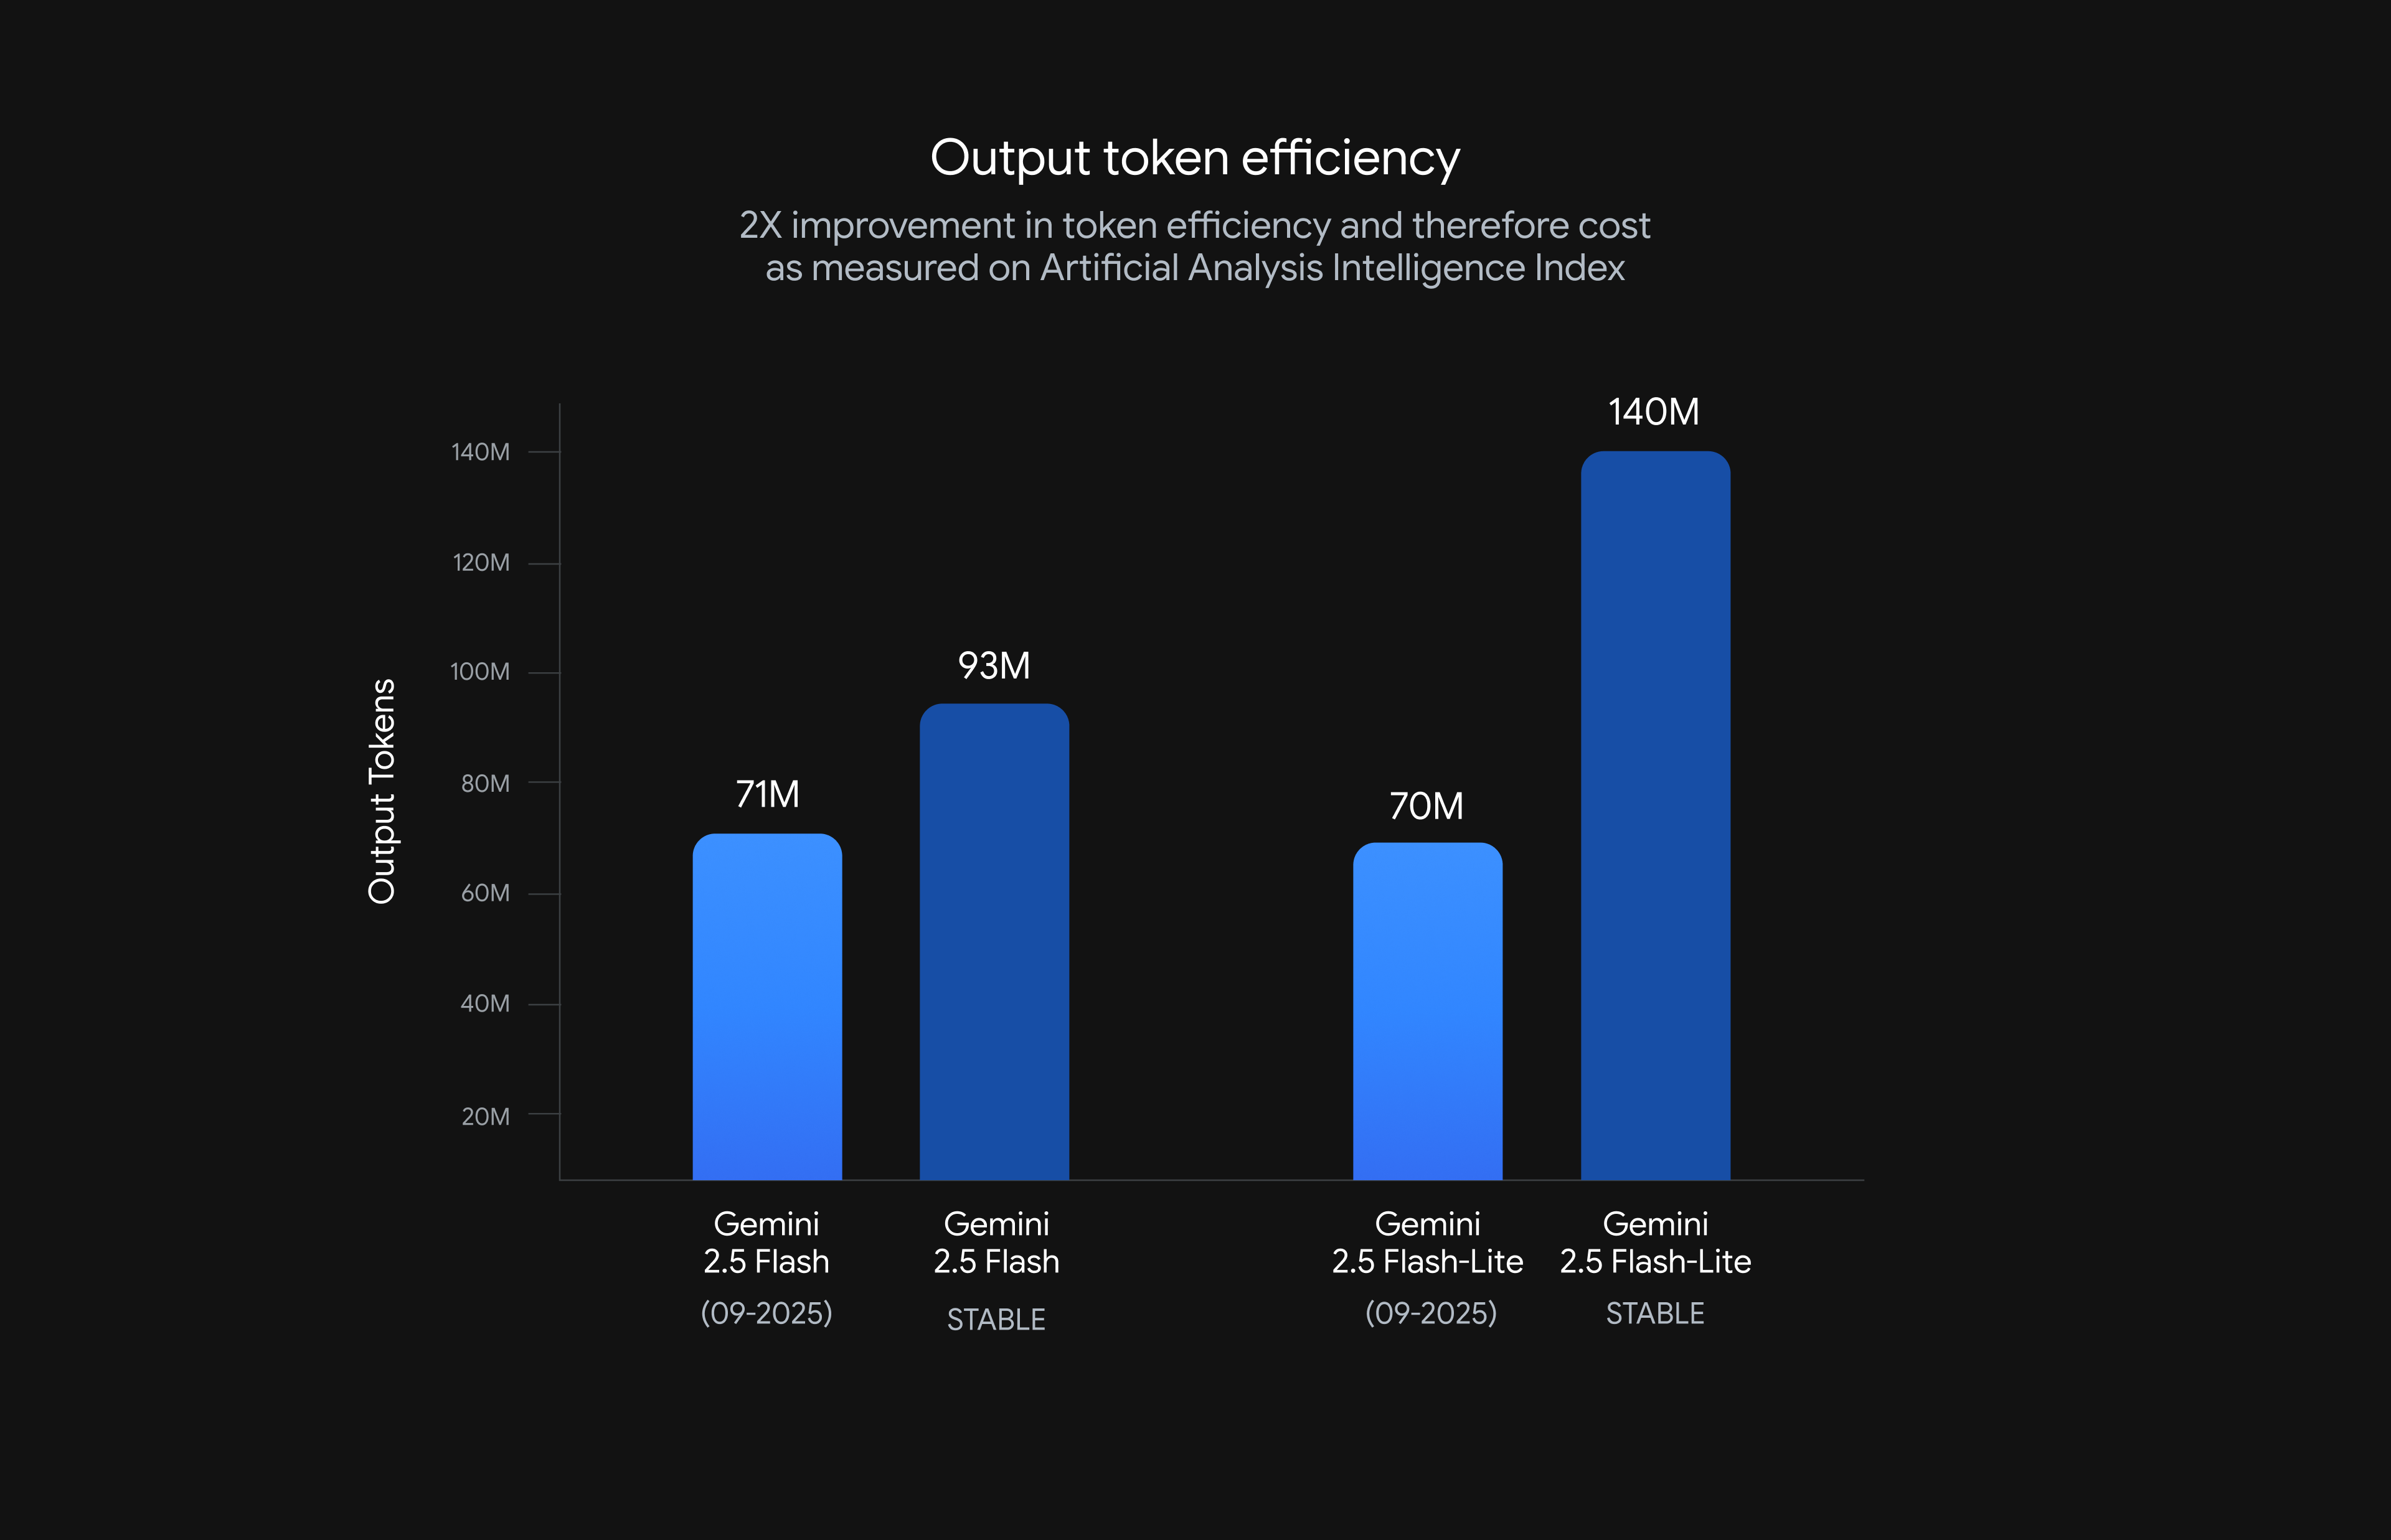
Gemini 2.5 Flash and Flash-Lite September 2025 previews achieve higher Artificial Analysis Intelligence Index scores and lower end-to-end response times than the previous stable models, both with and without thinking.

Quality, response time, and token usage on Artificial Analysis evaluations.
Gemini Flash update · September 2025 ↗
Planning with Models & Learning from Humans

Planning with models

Learning models for control, exploring without a task, and transferring what an agent learns to new objectives.

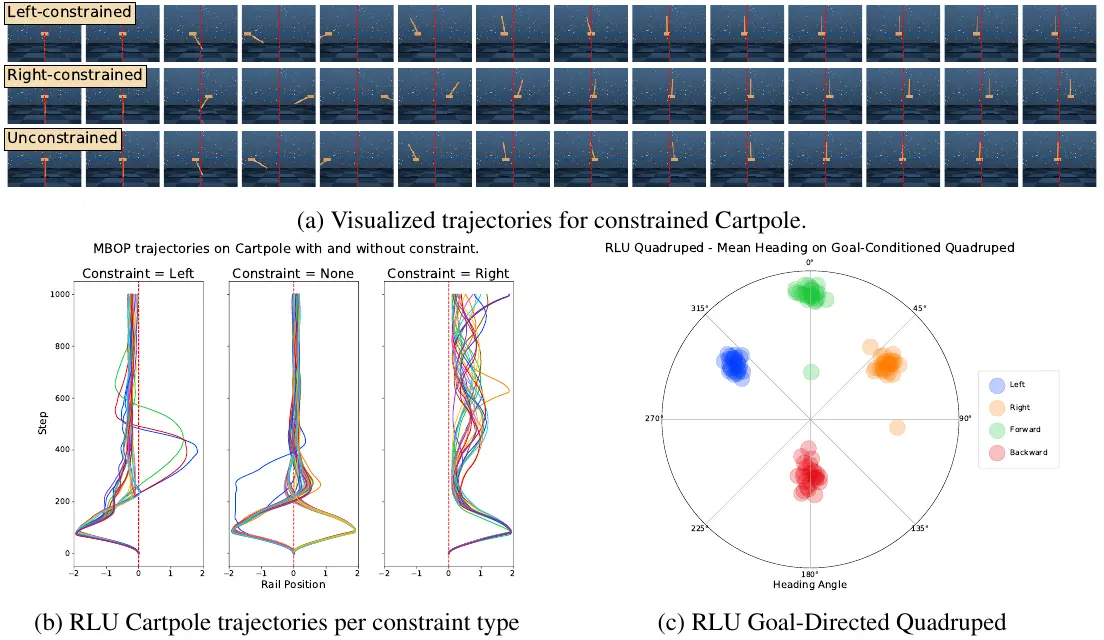
MBOP Figure 2: constrained Cartpole trajectories and goal-conditioned quadruped headings.
Model-Based Offline Planning ↗Fig. 2 · Constrained and goal-conditioned control

Learning from humans

Learning from demonstrations and human video.

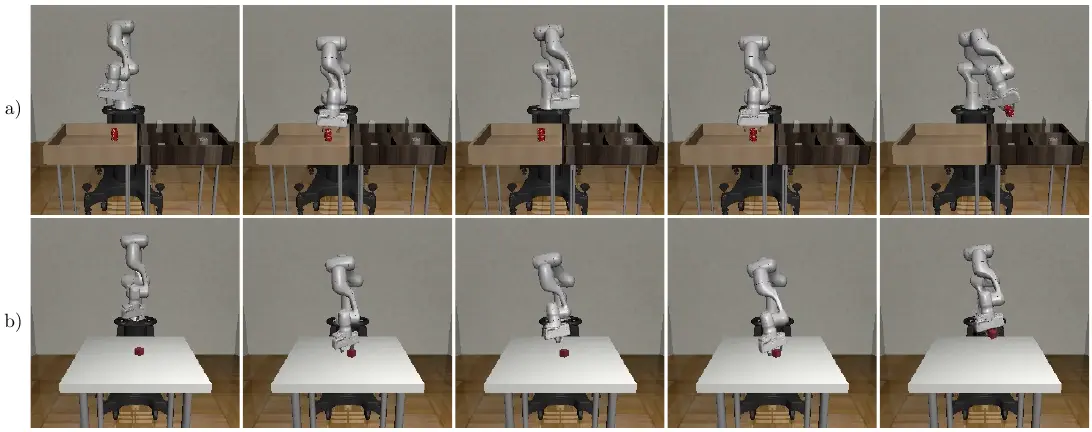
POIR Figure 8: robot sequences showing retries when picking up a can and lifting a block.
Get Back Here · Robust Imitation ↗Fig. 8 · Retrying after a missed grasp

Projects

Boats, cliffs, workshops.
Things built together.

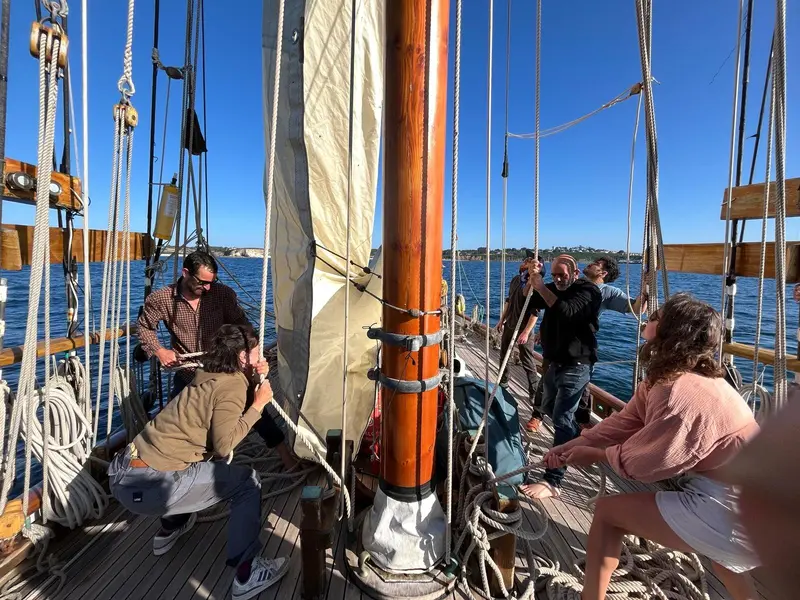
Crew handling the rigging aboard Pegasus.

Passeurs d’Iroise

Helped start and build a sail-training non-profit that owns Pegasus.

Visit project ↗
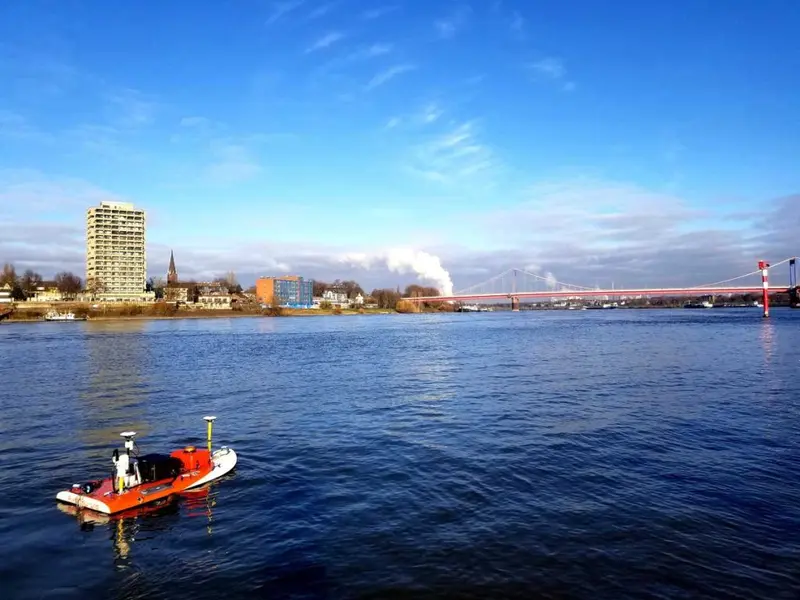
A small orange Riverdrone vessel on a river.

Riverdrone

Helped start an aquatic drone non-profit and bring its drones into production.

Visit project ↗

Mini-CV

2026–
Founding Research Scientist · UMA

Part of the AI team building general-purpose robots that can understand and act in the physical world.

2023–2026
Staff Research Scientist · Google DeepMind

Helped build and co-led one of the teams contributing to Gemini Thinking. Worked on reinforcement learning, reasoning, and the infrastructure for reliable experimentation.

2019–2023
Research Scientist · Google Brain

Led the real-world RL effort and projects on offline planning and learning from demonstrations. Also contributed to robotics research and applied ML collaborations in healthcare and marine biology.

2017–2019
Independent R&D · Blacksheep AI

Ran an independent consultancy, including robotics R&D for Nuro, where I built a complete grocery-picking demonstrator. Also worked with Air Street on technical due diligence.

2014–2017
Research Scientist · DeepMind

A founding research scientist in DeepMind’s Applied team, working on projects including a vision-based braking watchdog for Waymo. Helped start Google’s datacenter cooling project and co-invented the patented control approach.

Also co-initiated an industrial robotics project within DeepMind.

2010–2014
Ph.D., Computer Science · Sorbonne Université

Researched how reinforcement learning can make classifiers choose which information to acquire under a budget, with Ludovic Denoyer and Patrick Gallinari. Extended the approach to images, alongside teaching systems and introductory robotics.

2005–2010
Software Engineering · INSA Lyon

Earned an engineering degree in computer science in Lyon, before moving into reinforcement learning research.

Contact

For conversations about research, building things, or shared interests.

Based in Brittany, France.

GitHub ↗